|
SASC
DVBSoftCAM
|
|
SASC
DVBSoftCAM
|
#include <pat.h>
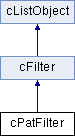
 Inheritance diagram for cPatFilter:
Public Member Functions | |
| cPatFilter (void) | |
| virtual void | SetStatus (bool On) |
| void | Trigger (void) |
Protected Member Functions | |
| virtual void | Process (u_short Pid, u_char Tid, const u_char *Data, int Length) |
| cPatFilter::cPatFilter | ( | void | ) |
| virtual void cPatFilter::Process | ( | u_short | Pid, |
| u_char | Tid, | ||
| const u_char * | Data, | ||
| int | Length | ||
| ) | [protected, virtual] |
Processes the data delivered to this filter. Pid and Tid is one of the combinations added to this filter by a previous call to Add(), Data is a pointer to Length bytes of data. This function will be called from the section handler's thread, so it has to use proper locking mechanisms in case it accesses any global data. It is guaranteed that if several cFilters are attached to the same cSectionHandler, only _one_ of them has its Process() function called at any given time. It is allowed that more than one cFilter are set up to receive the same Pid/Tid. The Process() function must return as soon as possible.
Implements cFilter.
| virtual void cPatFilter::SetStatus | ( | bool | On | ) | [virtual] |
Turns this filter on or off, depending on the value of On. If the filter is turned off, any filter data that has been added without the Sticky parameter set to 'true' will be automatically deleted. Those parameters that have been added with Sticky set to 'true' will be automatically reused when SetStatus(true) is called.
Reimplemented from cFilter.
| void cPatFilter::Trigger | ( | void | ) |
 1.7.3